FUNO
FUNO
At Positive Energy, we're committed to sustainability and ethical practices. From sourcing ingredients responsibly to minimizing our environmental footprint, we strive to make a positive impact.
At Positive Energy, we're committed to sustainability and ethical practices. From sourcing ingredients responsibly to minimizing our environmental footprint, we strive to make a positive impact.
HUMANOID SOCCER LEAGUE (HSL), MECHATRONICS RESEARCH LAB, QIAU
Year
3 month
Category
Application design
Live Project
View Now

Collaborative Design
Collaborative Design
/// Informing decision-making: Research provides data and evidence to support design decisions. It helps designers make informed choices about layout, color schemes, typography, and other design elements, leading to more effective and user-friendly websites
/// Informing decision-making: Research provides data and evidence to support design decisions. It helps designers make informed choices about layout, color schemes, typography, and other design elements, leading to more effective and user-friendly websites
" height="167px" id="cyqDoSKRd" width="1390px"/></g></svg>)
It’s not just me, it’s all of us!
MRL-HSL is made up of three main sub-teams
MRL-HSL is made up of three main sub-teams
MRL-HSL is made up of three main sub-teams

Electronics
Software

Mechanics

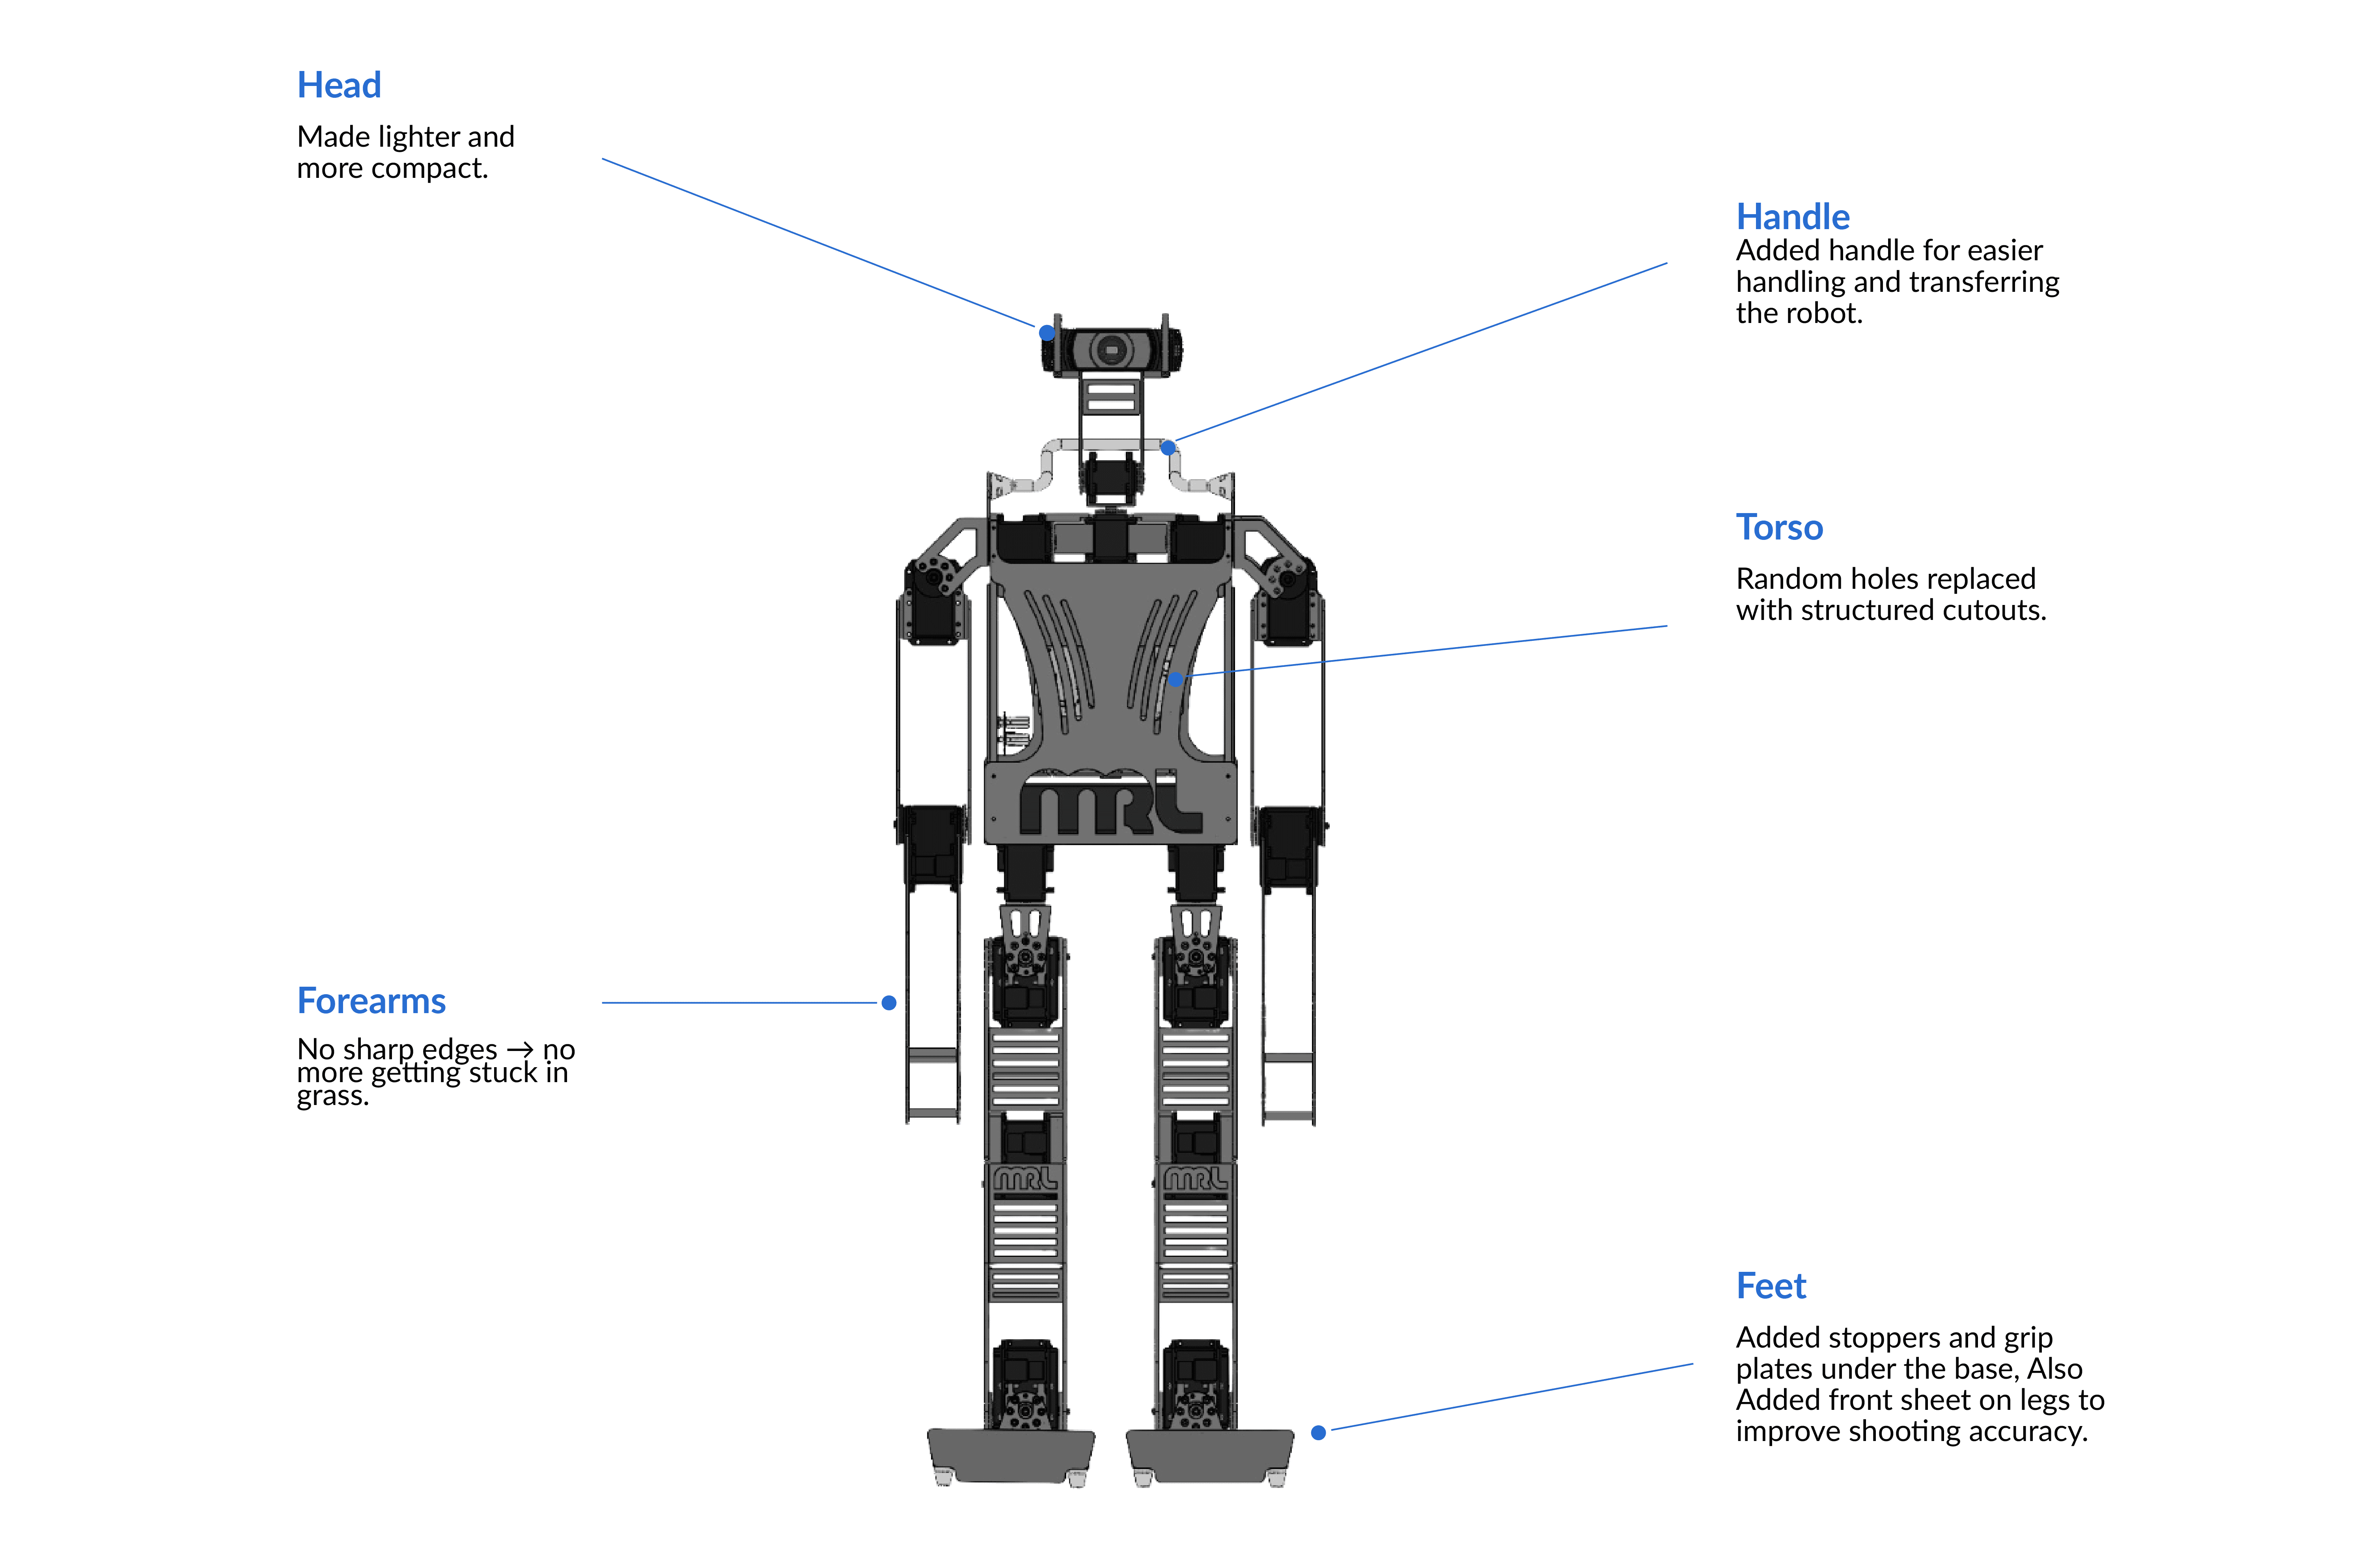
We began with a kid-size humanoid robot, but to compete in the Teen Size category we needed a completely new platform. I designed this robot by drawing inspiration from our kid-size model, as well as NAO, DARwIn-OP, and human golden-ratio proportionOPs.
The kid-size platform gave us a clear baseline for joint alignment, actuator range, and overall body proportions. Analyzing its performance on grass, weight distribution, and kicking stability helped define the mechanical requirements for the teen-size robot.
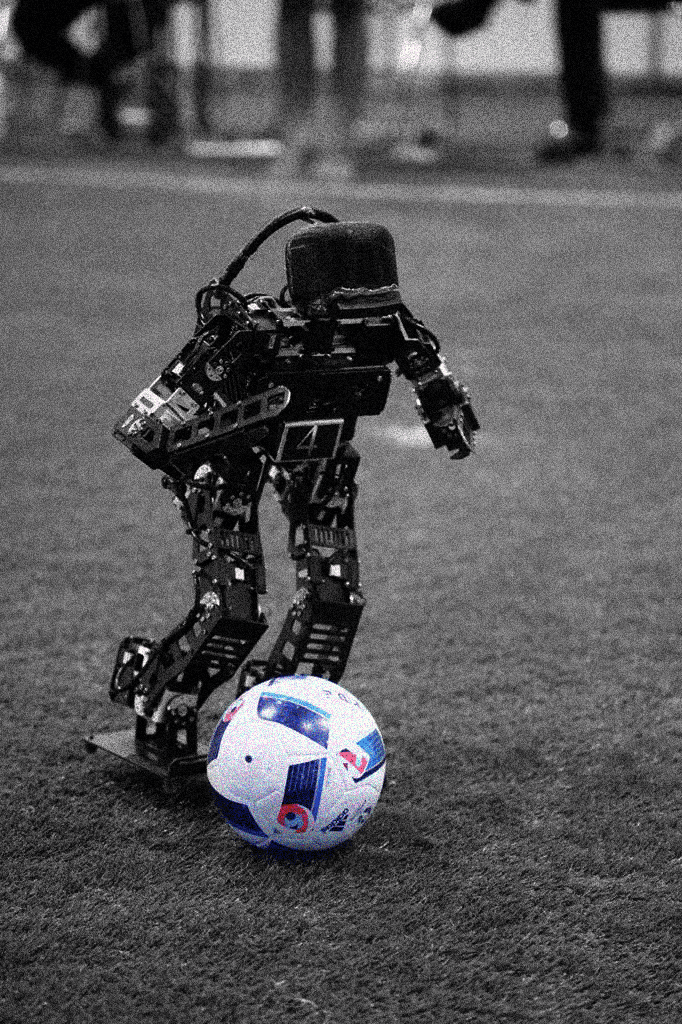
Kid-size robot
We began with a kid-size humanoid robot, but to compete in the Teen Size category we needed a completely new platform. I designed this robot by drawing inspiration from our kid-size model, as well as NAO, DARwIn-OP, and human golden-ratio proportionOPs.
The kid-size platform gave us a clear baseline for joint alignment, actuator range, and overall body proportions. Analyzing its performance on grass, weight distribution, and kicking stability helped define the mechanical requirements for the teen-size robot.
Kid-size robot
Foundation Research
Foundation Research
/// Informing decision-making: Research provides data and evidence to support design decisions. It helps designers make informed choices about layout, color schemes, typography, and other design elements, leading to more effective and user-friendly websites
/// Informing decision-making: Research provides data and evidence to support design decisions. It helps designers make informed choices about layout, color schemes, typography, and other design elements, leading to more effective and user-friendly websites

6061-T6 aluminum
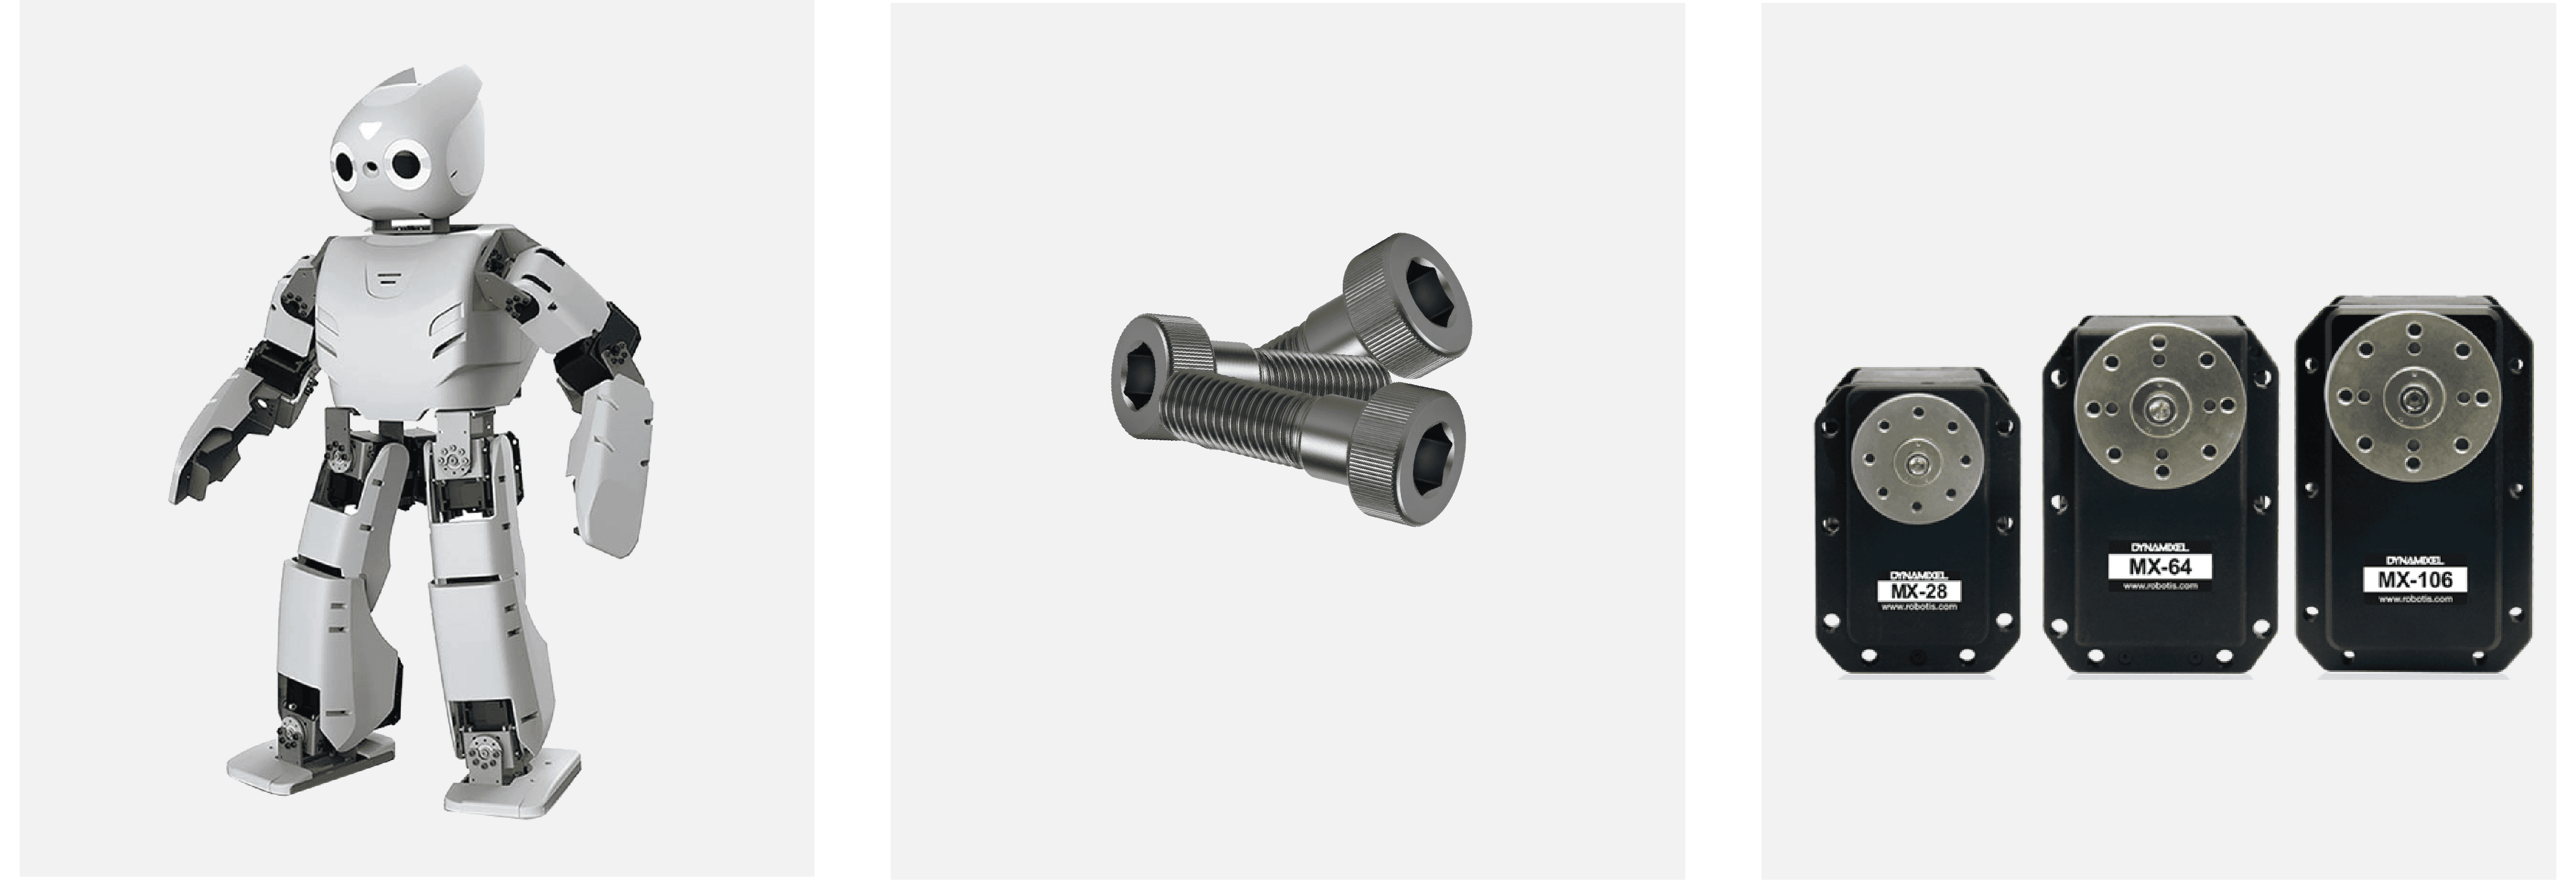
Studying Existing Platforms
Mechanical Joint Hardware
Actuator Selection
Prototype / Failed Version
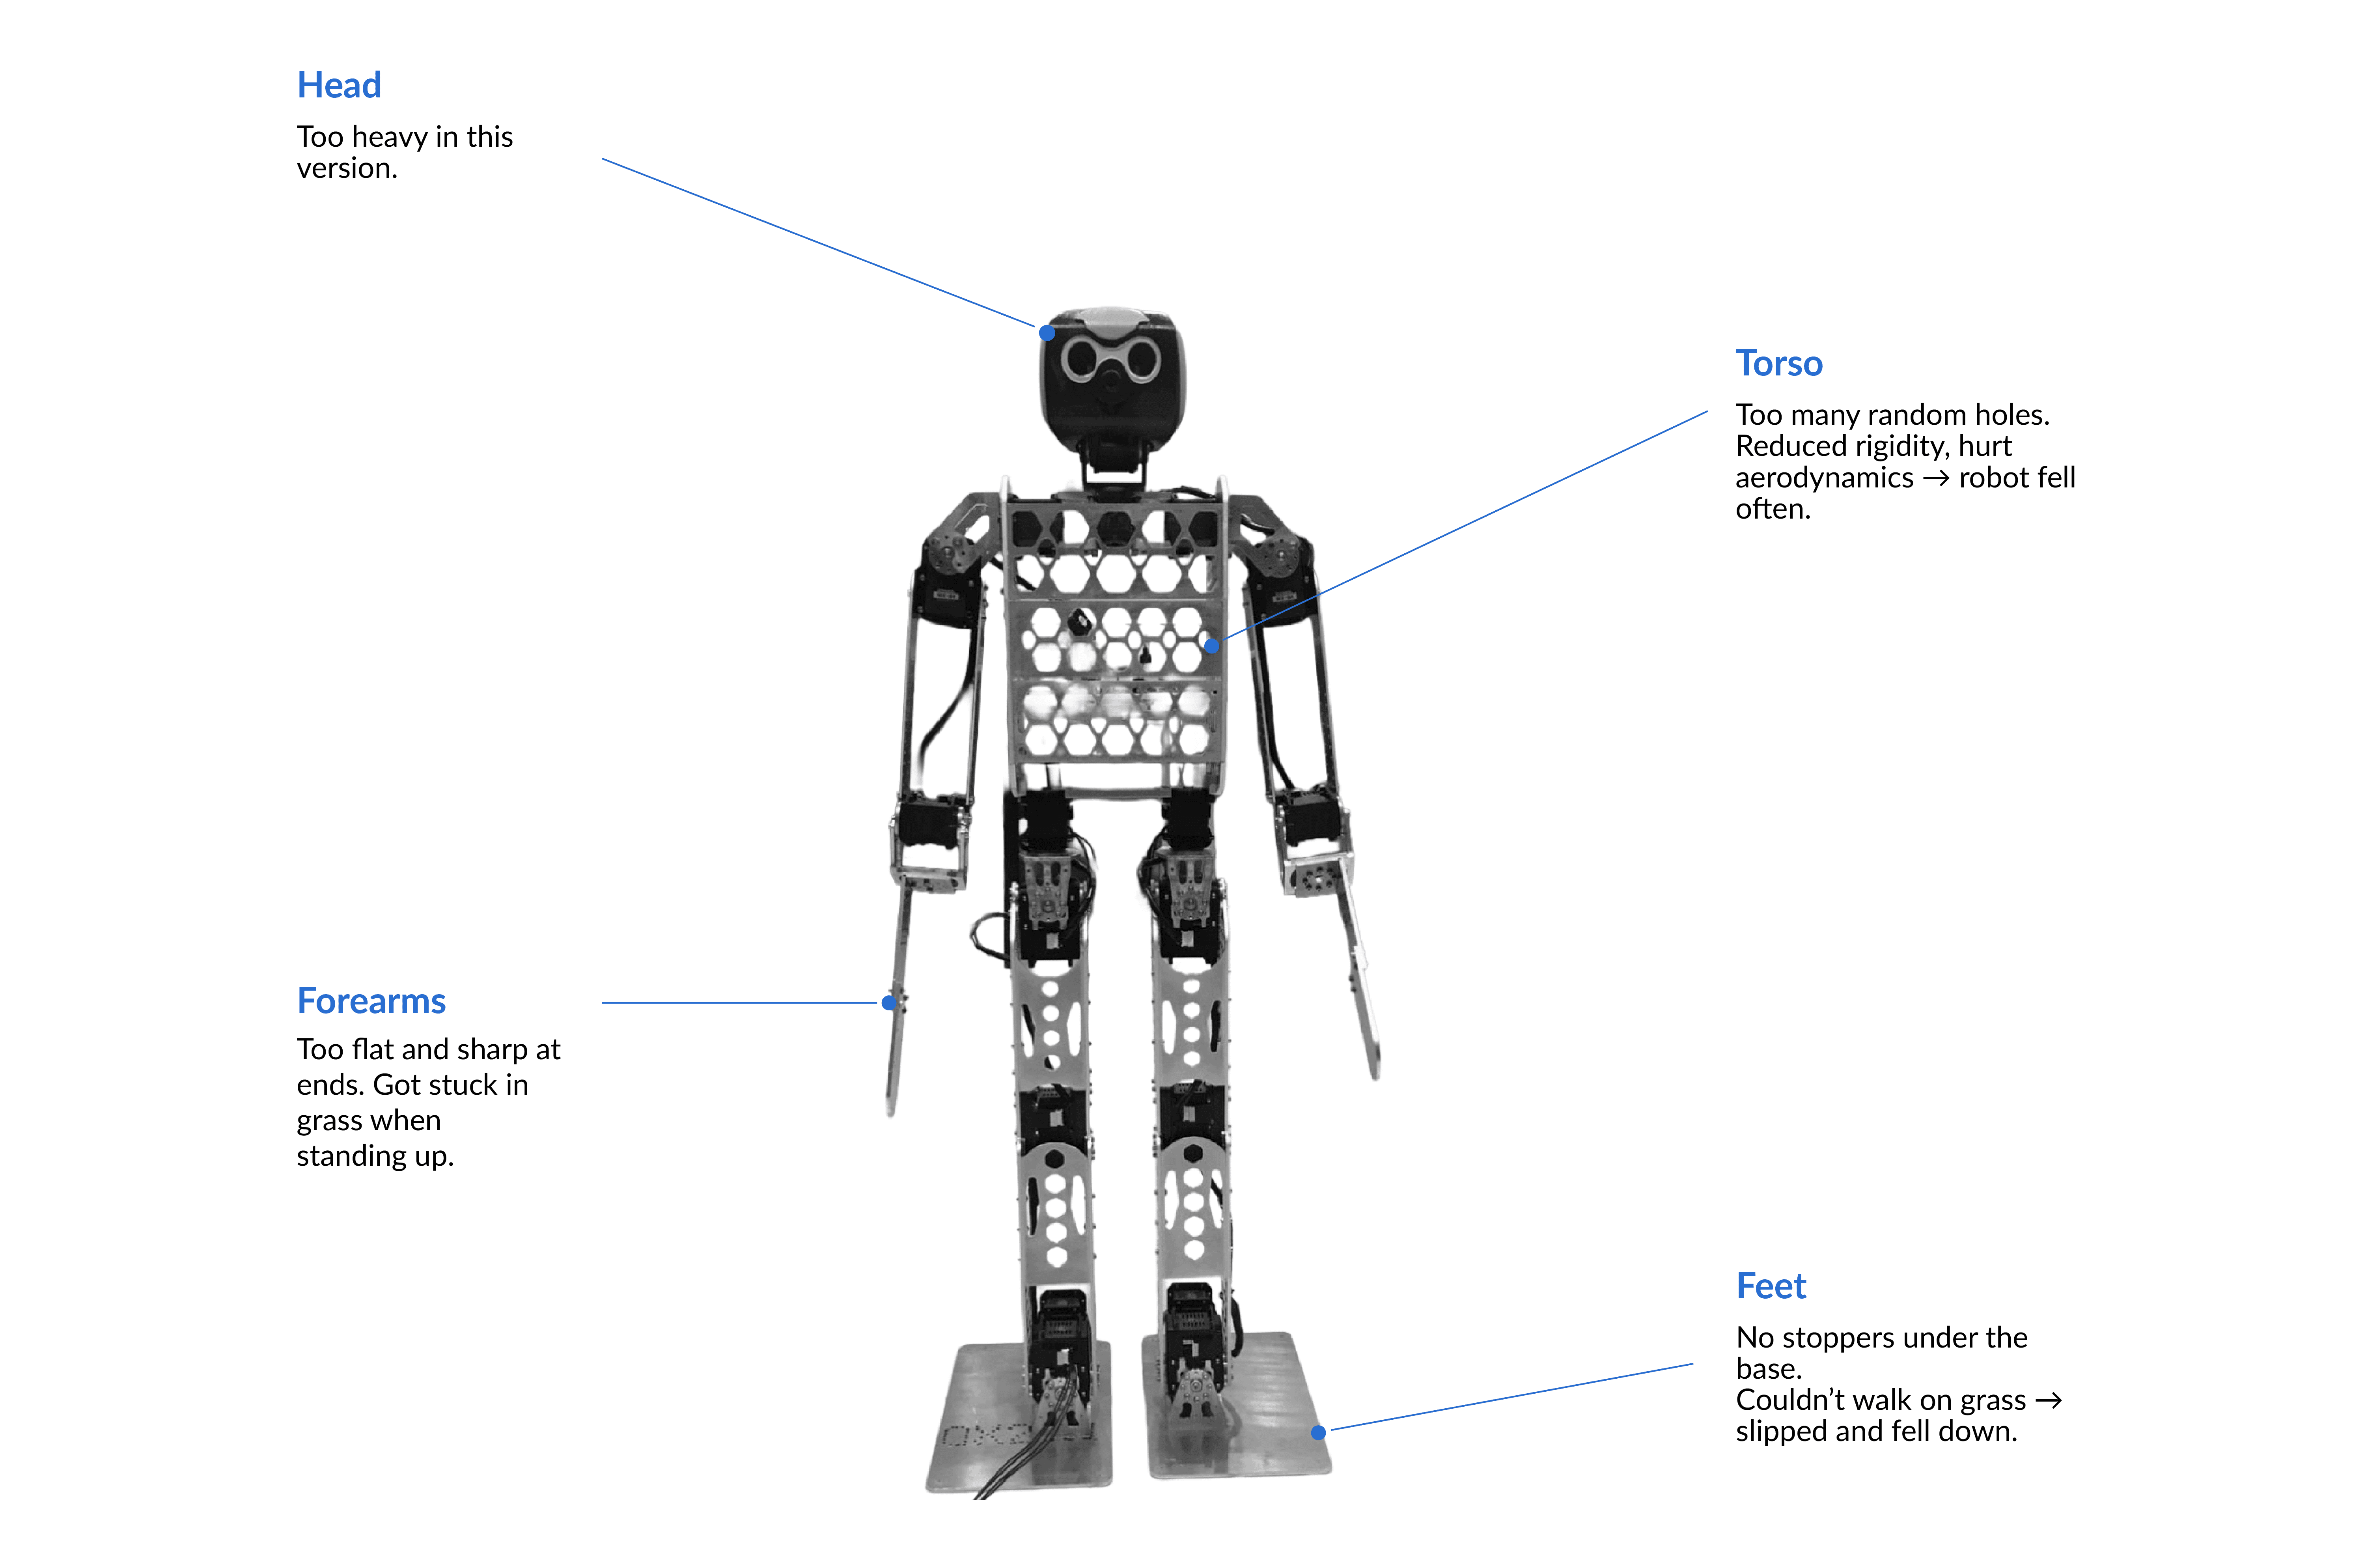
Final / Improved Version